
Compact cylinders in end-of-arm tooling ควรถูกเลือกเป็นส่วนหนึ่งของ robot payload ทั้งชุด ไม่ใช่ component ใน catalog แบบแยกตัว ให้รวม gripper หรือ cylinder body, fingers, mounting plate, sensors, valves, fittings, tubing, cables และ workpiece จากนั้นตรวจ center of gravity, inertia, grip force, wrist interface, cycle timing และ safe state หลัง air loss
Universal Robots นิยาม payload เป็นน้ำหนักรวมที่ติดกับ tool flange และต้อง configure center of gravity ของ payload นั้น (แนวทางเพย์โหลดของ Universal Robots, สืบค้นเมื่อ 2026-07-10) ดังนั้นคำว่า “gripper อยู่ต่ำกว่า robot payload” ยังไม่ใช่ approval statement ที่ครบถ้วน
ใช้ ISO pages ปัจจุบัน guidance จากผู้ผลิต robot และ catalog data เฉพาะ option เมื่อต้อง size compact cylinders สำหรับ EOAT หลีกเลี่ยง payload ratios, space-saving percentages, customer stories, fixed reservoir rules หรือ promotional comparisons ที่ไม่มี test evidence ตรงกับ project
EOAT payload คือ mass รวมที่ติดกับ robot flange รวม workpiece Combined center of gravity คือตำแหน่ง mass-weighted ของ payload ทั้งชุด Effective gripping force คือ finger force ที่ catalog นิยามไว้ที่ pressure, stroke position และ gripping-point distance ที่ระบุ
ประเด็นสำคัญ
- Robot payload รวม tool และ workpiece; ตัวอย่าง stack 2.30 kg มี combined CoG 114 mm (Universal Robots)
- คำนวณ inertia ก่อน estimate cycle time
- SMC นิยาม MHZ2 grip force ต่อ finger ที่ pressure และ contact distance ที่ระบุ
- Validate grip confirmation, energy isolation และ air-loss state บนเครื่องจริง
ในการเปรียบเทียบแหล่งข้อมูล ขอบเขตการออกแบบที่มีประโยชน์ชัดเจน: ISO 9409-1 ควบคุม flange interface, ผู้ผลิต robot ควบคุม payload และ inertia limits, catalog gripper ควบคุม finger force และ moment limits, ส่วน machine test พิสูจน์ว่า EOAT รวมถือชิ้นงานได้จริง
คำตอบสั้น: มอง EOAT เป็น Load และ Moment Budget
ตัวอย่าง EOAT component ห้ารายการด้านล่างรวม 2.30 kg และสร้าง combined center of gravity 114 mm จาก flange Universal Robots ระบุว่า payload ต้องรวม gripper และ workpiece พร้อม configure mass, center of gravity และ inertia ร่วมกัน (แนวทางเพย์โหลดสูงสุดของ Universal Robots)
มวลบรรทุกรวม = ผลรวมมวลของส่วนประกอบที่ติดตั้งทั้งหมดและชิ้นงาน
ระยะรวมถึงจุดศูนย์ถ่วง = ผลรวมของแต่ละค่า มวล x ระยะถึงหน้าแปลนของส่วนนั้น / total มวล
ค่าประมาณโมเมนต์สถิตที่หน้าแปลน = ผลรวมของแต่ละค่า มวล x ระยะถึงหน้าแปลนของส่วนนั้น
moment calculation ต่อไปนี้เป็น worksheet เพื่ออธิบาย ไม่ใช่ robot rating ให้แทนทุกค่าด้วย measured component mass และ drawing-based distance จริง คู่มือ robot ยังเป็น authority สำหรับ permitted mass, center-of-gravity envelope, moments, inertia, orientation และ acceleration
| Example item | Mass | Distance from flange | Mass x distance |
|---|---|---|---|
| Wrist adapter | 0.35 kg | 20 mm | 0.0070 kg m |
| Valve and sensors | 0.15 kg | 45 mm | 0.0068 kg m |
| Pneumatic gripper | 0.55 kg | 70 mm | 0.0385 kg m |
| Fingers and pads | 0.25 kg | 120 mm | 0.0300 kg m |
| Workpiece | 1.00 kg | 180 mm | 0.1800 kg m |
| Total | 2.30 kg | Combined CoG: 114 mm | 0.2623 kg m |
Actuator ที่เบากว่าไม่ได้ดีกว่าโดยอัตโนมัติ การย้าย finger mass 250 g ให้ใกล้ flange อีก 50 mm อาจช่วย mass-distance budget มากกว่าการลด 250 g จาก valve ที่ติดใกล้ flange น้ำหนักที่ลดลงมีค่ามากขึ้นเมื่อทำให้ center-of-gravity offset สั้นลงด้วย
อะไรนับรวมใน Robot Payload และ Wrist Moment?
ISO 9409-1:2004 เป็น interface standard 6 หน้า ยืนยันในปี 2023 มันนิยาม circular plate dimensions, designation และ orientation แต่ระบุชัดว่าไม่ให้ load-carrying correlation (ISO 9409-1, confirmed 2023) ดังนั้น bolt circle ที่ตรงกันพิสูจน์ fit เชิงกล ไม่ได้พิสูจน์ robot payload หรือ wrist capacity
ให้นับ adapter plate, quick changer, compliance device, fasteners, compact cylinder หรือ pneumatic gripper body, custom fingers, pads, stops, guards, retained hardware, valve, manifold, sensors, connectors, fittings, cable brackets, service loops ที่ manual ต้องนับ และ workpiece ที่หนักที่สุดพร้อม tolerances จากนั้น locate center of mass ของแต่ละชิ้นจาก flange coordinate system Robot controllers ใช้ payload data เพื่อ compensate motion และ Universal Robots เตือนว่า acceleration อาจถูกลดลงเมื่อ center of gravity ออกนอก rated envelope
ISO 9283 ครอบคลุม robot performance criteria และ corresponding test methods ใน standard 60 หน้า ซึ่งยัง current หลัง confirmation ปี 2021 (ISO 9283:1998) แต่ให้ใช้ model-specific data ของผู้ผลิต robot สำหรับ payload, wrist moment, inertia และ performance envelope จริง
คำนวณ Grip Force ระหว่าง Robot Acceleration อย่างไร?
ตัวอย่าง selection ของ SMC MHZ คูณน้ำหนัก workpiece 0.1 kg ด้วย 20 และได้ required gripping force 19.6 N พร้อมเตือนว่า high acceleration, deceleration หรือ impact ต้องมี margin เพิ่ม (SMC MHZ catalog, current catalog) ให้ถือกฎนั้นเป็น manufacturer guidance ไม่ใช่ universal friction calculation
แรงยึดที่ต้องการ ต่อปากจับ = m x (g + a) x S / (n x สัมประสิทธิ์แรงเสียดทาน)สำหรับ friction grip ภายนอกแบบสมดุลสอง jaws ค่า `m` คือ workpiece mass, `a` คือ acceleration ในทิศ slip, `S` คือ design factor และ `n` คือจำนวน effective contact faces สมการนี้สมมติ jaw loading เท่ากันและเป็น friction grip ง่ายๆ ไม่ครอบคลุม form closure, angled contact, impact, rotation หรือ uneven pads สำหรับ vertical pick 1.0 kg สอง jaws, สัมประสิทธิ์แรงเสียดทาน 0.40 และ design factor 2.0 required force เพิ่มจาก 24.5 N ต่อ jaw ที่ rest เป็น 49.5 N ต่อ jaw ที่ acceleration 10 m/s2
Compact Actuator Architecture ใดเหมาะกับงาน EOAT?
SMC MHZ2 family ครอบคลุม bore 6-40 mm; catalog ระบุสูงสุด 180 รอบต่อนาที สำหรับ sizes 6-25 mm และ 60 สำหรับ 32-40 mm (SMC MHZ catalog) ค่าเหล่านี้เป็น model limits ภายใต้ catalog conditions ไม่ใช่ robot-cell throughput ที่รับประกัน
| Tooling task | Better starting architecture | Main verification |
|---|---|---|
| จับ part ระหว่าง fingers เคลื่อนที่ | Pneumatic gripper | Per-finger force, finger moment, stroke, part damage |
| ดัน stop, pin, latch หรือ ejector | Compact cylinder | Bore force, rod side load, stroke, end impact |
| เคลื่อน offset plate หรือ nest | Guided compact cylinder | โมเมนต์ที่ชุดนำทางs, alignment, moving mass |
| เข้าถึงตาม tool ยาวแคบ | Rodless or guided slide | Carriage moments, seal/guide limits, envelope |
| ใช้ programmable positions หรือ profiles | Electric or servo-pneumatic axis | Feedback, controller, repeatability, safe stop |
ตัวอย่างเช่น compact cylinder อาจ operate locating pin ขณะที่ pneumatic gripper แยกต่างหากจับ part แต่ robot ยังมองอุปกรณ์ทั้งสอง adapter และ workpiece เป็น payload configuration เดียว
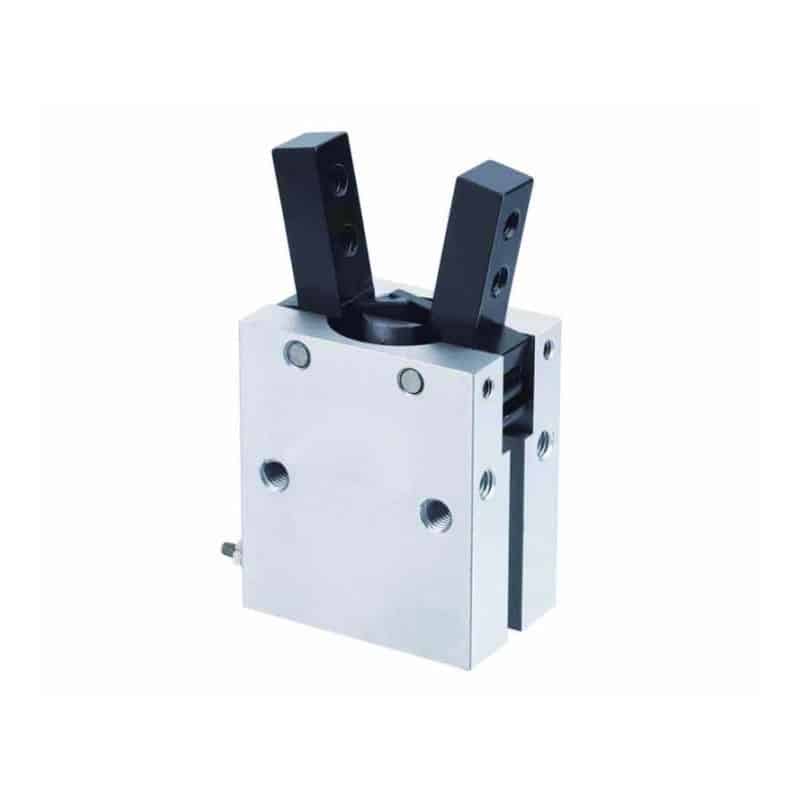
XHC parallel pneumatic gripper
ส่วนนี้ตั้งใจไม่เป็น catalog ของ gripper types อีกชุดหนึ่ง สำหรับ parallel, angular, three-jaw, toggle และ wide-opening selection ใช้ pneumatic gripper types guide ที่มีอยู่ สำหรับตัวอย่าง compact-cylinder ระดับ station นอก robot wrist ดู compact cylinders in PCB assembly
ควบคุม Finger Length, Offset และ Jaw Moment อย่างไร?
ตัวอย่าง MHZ2 ของ SMC ระบุ 24 N ที่ 0.4 MPa ด้วย gripping-point distance 30 mm และนิยาม effective gripping force เป็น thrust ของ one finger (SMC MHZ catalog) body เดียวกันอาจมี usable force และ guide load ต่างกันเมื่อ fingers ยาวขึ้น
ตรวจสี่ค่าต่างหาก: per-finger gripping force จาก catalog graph ที่ pressure และ gripping-point distance จริง, finger โมเมนต์ที่ชุดนำทาง จาก force ที่ contact offset รวม robot acceleration/impact, contact pressure จาก clamping force หาร pad area และเทียบ damage limit ของ workpiece, และ finger stiffness เพื่อยืนยัน deflection ไม่พา part ออกจาก process หรือ sensor window
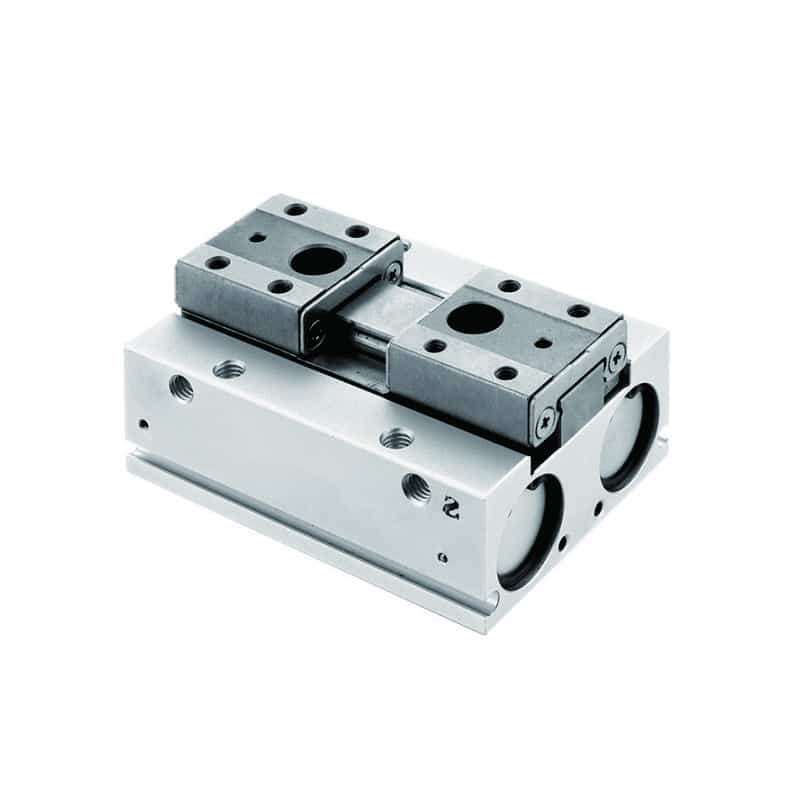
XHF low-profile parallel pneumatic gripper
ถ้า catalog force เพียงพอแต่ fingers เกิน length หรือ moment ที่อนุญาต ให้ใช้ fingers สั้นลง ย้าย contact ให้ใกล้ขึ้น เพิ่ม form-closed features เพิ่ม pad area หรือเลือก gripper ที่ guide แข็งกว่า การเพิ่ม pressure อย่างเดียวอาจเพิ่ม part marking โดยไม่แก้ finger deflection ให้ถือ contact point เป็น design variable body ที่ compact แต่ fingers ยาวอาจสร้าง load path ที่ไม่ compact เท่า gripper ใหญ่กว่าเล็กน้อยซึ่ง jaws ไปถึง part โดยไม่ต้องมี adapter
Mounting, Routing และ Service Envelope
ISO 9409-1 ถูกยืนยันในปี 2023 และใช้เพียง 6 หน้าเพื่อ define circular mechanical interface พร้อมระบุว่า standard ไม่ correlate interface size กับ load capacity (ISO 9409-1) ดังนั้น mounting plate ต้อง satisfy robot manual, tool load, fastener, stiffness และ locating requirements แยกต่างหาก
Model envelope ทั้งใน jaw positions สองด้านและตลอด robot path รวม fittings, speed controllers, sensor connectors, tube bend radius, cable strain relief, fastener access, quick-change motion และพื้นที่ถอด gripper โดยไม่ต้องรื้อ wrist Route flexible services ไม่ให้กลายเป็น hidden load tube loop ที่ตึงดึง gripper ขนาดเล็กได้ ส่วน loop ที่ใหญ่เกินไปอาจ snag fixture หรือเข้ากล้อง จัด anchor service bundle ใกล้ wrist ให้ repeated bending อยู่ใน flex zone และ verify ทุก extreme robot pose ใช้ dowels หรือ locating features เมื่อ tool orientation ต้อง repeat ได้ Fasteners ให้ clamp load ไม่ควรให้ locate precision EOAT ผ่าน clearance holes เพียงอย่างเดียว
Valves, Tubing และ Sensors ส่งผลต่อ Timing อย่างไร?
SMC ระบุ 180 รอบต่อนาที สำหรับ MHZ2 bore 6-25 mm และ 60 รอบต่อนาที สำหรับ 32-40 mm แต่เป็น maximum catalog frequencies (SMC MHZ catalog) timing จริงยังขึ้นกับ valve flow, tube volume, pressure during motion, finger mass, sensors และ PLC sequence
วาง valve ใกล้ wrist เมื่อ pneumatic volume ที่สั้นลงช่วย response อย่างมีนัยสำคัญ แต่รวม valve mass, cable mass, heat, ingress protection และ service access ใน payload budget Remote valve island ลด wrist mass แต่เพิ่ม tube volume ไม่มี arrangement ใดชนะโดยอัตโนมัติ วัด events แยกกัน: robot reaches permitted grip pose, valve output changes state, gripper closes enough to contact part, pressure/position confirms valid grip, robot motion permission issued, release completes before robot leaves place position
อย่าใช้ fixed delay เป็น grip confirmation เพียงอย่างเดียวเมื่อ dropped part สร้าง hazard หรือ quality risk Position switches ยืนยัน jaw state ได้แต่อาจไม่พิสูจน์ part retention Pressure logic detect faults บางอย่างได้แต่ต้องมี thresholds, timing และ fault handling ที่กำหนดไว้ คู่มือ solenoid valve operation guide อธิบาย valve states และ pneumatic pressure-drop guide อธิบาย losses ระหว่าง ท่อเมนของโรงงาน กับ moving tool
EOAT ควรใช้ Safe State และ Acceptance Tests แบบใด?
ISO/TR 20218-1:2018 เป็น safety-design guide 25 หน้าเกี่ยวกับ robot end-effectors ส่วน ISO 10218-2:2025 เป็น standard 223 หน้าเกี่ยวกับ industrial robot applications and cells (ISO/TR 20218-1; ISO 10218-2:2025) safe state ของ EOAT ต้องมาจาก risk assessment ไม่ใช่กฎ universal ว่าต้อง “open” หรือ “closed”
ถามว่าเกิดอะไรขึ้นเมื่อ air pressure, electrical power, communication, sensor หรือ tube fail การทำ heavy/sharp part หล่นอาจเป็น hazard หลัก ใน process อื่น การ retain part ที่ร้อนหรือปนเปื้อนอาจแย่กว่า เลือก spring assist, pilot-operated checks, mechanical retention, controlled release หรือ redundant sensing หลัง failure analysis เท่านั้น ก่อน production release ให้รัน first-article test ที่บันทึก EOAT mass และ payload data ครบ, wrist interface/fasteners/stiffness/service access, grip assumptions/finger length/contact pressure/moment approval, dynamic picks ที่ acceleration ต่ำ ปกติ และสูงที่ credible, part-present/jaw-position/pressure/robot-permission timing, safe response ต่อ air loss/power loss/sensor faults/E-stop และ repeatability หลัง tool changes กับ service bundle flexed
สำหรับ servicing และ maintenance ในสหรัฐฯ OSHA 29 CFR 1910.147 ใช้เมื่อ unexpected energization, startup หรือ stored-energy release อาจทำให้บาดเจ็บ (OSHA 1910.147) Commissioning tests ไม่แทน energy-control procedure ของไซต์
FAQ เกี่ยวกับ Compact Cylinders ใน End-of-Arm Tooling
SMC ระบุ operating-pressure ranges ของ MHZ2 ตั้งแต่ 0.1 ถึง 0.7 MPa สำหรับ double-acting 16-40 mm models หลายรุ่น และ identify gripping force per finger (SMC MHZ catalog) FAQ เหล่านี้ครอบคลุม system checks ที่ยังเหลือหลัง shortlist compact actuator แล้ว
EOAT ที่เบากว่าช่วย cycle time ของ robot เสมอหรือไม่?
ไม่ mass ที่ต่ำลงช่วยได้ แต่ center of gravity และ inertia ก็ควบคุม motion envelope ที่ใช้ได้เช่นกัน ในตัวอย่าง 2.30 kg ที่ combined offset 114 mm ยังต้องตรวจเทียบ load diagram ของ robot ที่เลือก Finger reach และ workpiece position อาจสำคัญกว่า body mass
คำนวณ center of gravity ของ EOAT อย่างไร?
นำ mass ของแต่ละ component คูณระยะจาก flange รวมผลคูณเหล่านั้น แล้วหารด้วย total mass ตัวอย่างให้ 0.2623 kg m หารด้วย 2.30 kg หรือประมาณ 114 mm สำหรับ controller data จริงให้ใช้ coordinates สามมิติและ inertia method ของผู้ผลิต robot
ISO 9409-1 พิสูจน์ว่า EOAT รับ load ได้หรือไม่?
ไม่ ISO 9409-1 6 หน้า define circular plate interface, designation, marking, exchangeability และ orientation แต่ระบุชัดว่าไม่ correlate interface กับ load-carrying ranges Payload, center of gravity, moments, inertia, fasteners และ adapter stiffness ยังต้อง verify เฉพาะรุ่น
Robot EOAT ต้องใช้ gripping force เท่าใด?
ขึ้นกับ mass, acceleration direction, friction, jaw count, contact geometry, finger offset, impact และ design factor ที่เลือก ตัวอย่าง 0.1 kg ของ SMC ใช้ 20 เท่าของ workpiece weight และได้ 19.6 N ให้ใช้เป็น catalog guidance แล้ว validate part จริงและ robot path
หลังสูญเสียลม gripper ควรเปิดหรือปิดค้าง?
ไม่มีคำตอบสากล ISO/TR 20218-1 มี guidance ด้าน end-effector safety 25 หน้า และ ISO 10218-2:2025 ครอบคลุม robot-cell integration ให้กำหนด state ที่ปลอดภัยกว่าจาก dropped-part, retained-part, pinch, thermal, contamination, recovery และ stored-energy hazards แล้วทดสอบ architecture ที่เลือก
บทสรุป: อนุมัติ Tool เป็นระบบเดียว
ตัวอย่าง EOAT รวม 2.30 kg ที่ combined offset 114 mm ขณะที่ workpiece 1 kg ต้องการ illustrative 49.5 N ต่อ jaw ที่ 10 m/s2 ภายใต้ friction และ design-factor assumptions ที่ระบุ Universal Robots และ SMC ต่างแสดงว่า mass, center of gravity, pressure, contact point และ force ต้องได้รับ approval ร่วมกัน
Freeze tool เป็น configuration เดียว: robot model, flange, adapter, actuator, fingers, valve, sensors, fittings, service bundle, workpiece range, payload data, motion limits, grip logic และ failure response การแทน compact cylinder หรือ gripper รุ่นอื่นยอมรับได้ก็ต่อเมื่อ evidence package ทั้งชุดยังผ่าน สำหรับ machine-specific review ส่ง robot model, load diagram, EOAT CAD, component masses, center-of-mass coordinates, part drawing, acceleration profile, pressure at valve, finger geometry, sensor logic และ safe-state requirement ผ่าน หน้าติดต่อ ข้อมูล publisher อยู่ใน หน้าเกี่ยวกับเบปโต นิวเมติก
แหล่งข้อมูลและบันทึกการสืบค้น
- ISO 9409-1:2004, สืบค้นเมื่อ 2026-07-10
- ISO 9283:1998, สืบค้นเมื่อ 2026-07-10
- ISO/TR 20218-1:2018, สืบค้นเมื่อ 2026-07-10
- ISO 10218-2:2025, สืบค้นเมื่อ 2026-07-10
- แนวทางเพย์โหลดของ Universal Robots, สืบค้นเมื่อ 2026-07-10
- แนวทางเพย์โหลดสูงสุดของ Universal Robots, สืบค้นเมื่อ 2026-07-10
- แค็ตตาล็อกกริปเปอร์ลมแบบขนาน SMC MHZ, สืบค้นเมื่อ 2026-07-10
- OSHA 29 CFR 1910.147, สืบค้นเมื่อ 2026-07-10
- Universal Robots Academy, การกำหนดค่าเครื่องมือ: TCP ทิศทาง เพย์โหลด และจุดศูนย์ถ่วง, อัปโหลดเมื่อ 2021-12-16